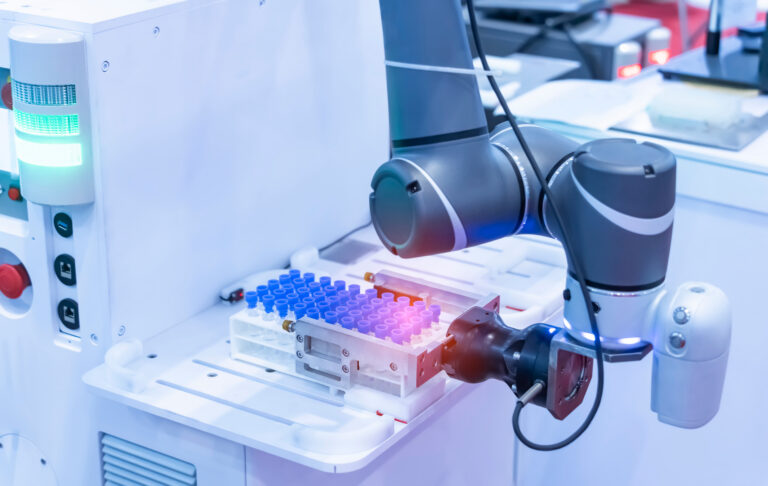
- Frameless motors are increasingly utilized in both industrial and collaborative robots, enhancing their performance and capabilities.
- The integration of advanced gearing systems, such as cycloidal and strain-wave gearing, is critical for optimizing torque and precision across various robotic applications.
- Miniature robotics are advancing with custom components that improve maneuverability and repeatability, showcasing the importance of tailored motor designs.
The evolution of motor design in robotics is pivotal, particularly as industries seek to enhance efficiency and precision in automation. The shift towards frameless motors in both industrial six-axis robots and collaborative robots underscores a significant trend in the robotics sector, where the demand for compact, high-performance solutions continues to grow. This convergence not only improves the functionality of robotic systems but also allows for greater flexibility in applications ranging from assembly to inspection.
Recent advancements highlight the dominance of permanent-magnet brushless servomotors, particularly in six-axis robotic assemblies. These motors, often paired with high pole counts and strain-wave gearing, deliver impressive torque output while minimizing cogging. The integration of absolute encoders for closed-loop control and safety brakes further enhances operational safety and precision, making these systems more reliable for complex tasks. The ability to customize rotor geometry and windings allows for tailored performance based on the specific payload and operational requirements, which is crucial for applications that demand high accuracy.
Moreover, the use of advanced gearing systems such as cycloidal and strain-wave gearing is becoming increasingly common. These systems are essential for achieving high torque and power density, particularly in articulated arms and SCARA robots. The choice of gearing directly impacts the robot's ability to handle varying payloads and perform tasks with precision. For instance, the right-angle hypoid gearboxes used in seventh-axis systems are designed to optimize space and enhance torque delivery, which is vital for maintaining performance under load. This adaptability in gearing not only improves efficiency but also extends the operational lifespan of robotic systems.
In the realm of miniature robotics, the integration of custom components is revolutionizing the capabilities of small-scale robotic arms. These systems, which can handle payloads of up to 0.5 kg with high maneuverability, rely on advanced motor designs and dual-feedback systems to ensure repeatability and precision. The emphasis on tailored solutions in miniature robotics reflects a broader trend towards customization in the industry, where specific applications require unique configurations to meet performance standards. As robotics technology continues to advance, the interplay between motor design, gearing systems, and application-specific requirements will be critical in shaping the future of automation.